Video Teratas
Pencarian Teratas
Baru Dilihat
Suasana & Genre
Autumn
Chill
Commute
Energize
Feel good
Focus
Gaming
Party
Romance
Sad
Sleep
Summer
Winter
Workout
African
Arabic
Blues
Bollywood & Indian
Classical
Country & Americana
Dance & electronic
Decades
Family
Folk & acoustic
German hip-hop
German pop
Hip-hop
Indie & alternative
J-Pop
Jazz
K-Pop
Latin
Mandopop & cantopop
Metal
Pop
R&B & soul
Reggae & caribbean
Rock
Schlager
Soundtracks & musicals
Akun Saya
Masuk
Daftar Putar Saya
Statistik Saya
Unggah
Blog
ID
English
Español
Français
Bahasa Indonesia
Português
Türkçe
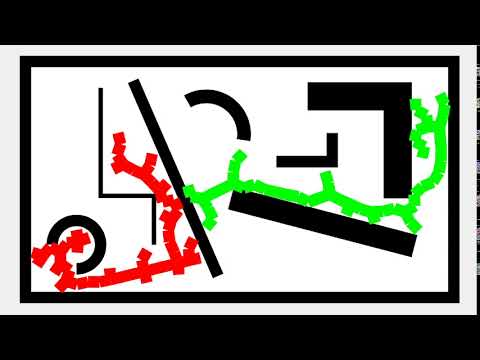
Robot Path Planning: RRT* v/s BIT*
0:56
|
Memproses video...
Memuat...
Unduh
Video Berikutnya
RRTX: Dubins Vehicle in R^2 x S Dynamic Environment (Forest)
0:21
|
Video Terkait
5:41
Motion Planning Algorithms (RRT, RRT*, PRM) - [MIT 6.881 Final Project]
0:46
Multimedia Extension 1 - AIT* compared to RRT*, FMT*, and BIT* when minimizing path length
0:11
RRT Connect animation
1:01
Informed RRT* @ UTIAS (2014)
0:21
RRTX: Dubins Vehicle in R^2 x S Dynamic Environment (Forest)
1:26
Our implementation of Real-time RRT* with multi-query support
9:00
Advanced Robot Path Planning (RRT)
0:46
Multimedia Extension 2 - EIT* compared to RRT*, BIT*, and AIT* when optimizing obstacle clearance
2:56
Informed RRT* @ UTIAS (IROS 2014)
1:45
Batch Informed Trees (BIT*) @ UTIAS / CMU (ICRA 2015)
0:09
[PythonRobotics] Batch Informed RRT* path planning
0:21
[PythonRobotics] RRT* with dubins path
0:39
RRTX: Dubins Vehicle in R^2 x S Dynamic Environment
1:49
AIT* and EIT*: Asymmetric bidirectional sampling-based path planning - IJRR 2022 @ ORI
0:15
RRT Path Planning with Kinodynamic Trajectory Generation
1:50
RABIT* @ CMU (ICRA 2016)
0:32
RRT vs RRT* - 2D environment with Polygonal Obstacles